

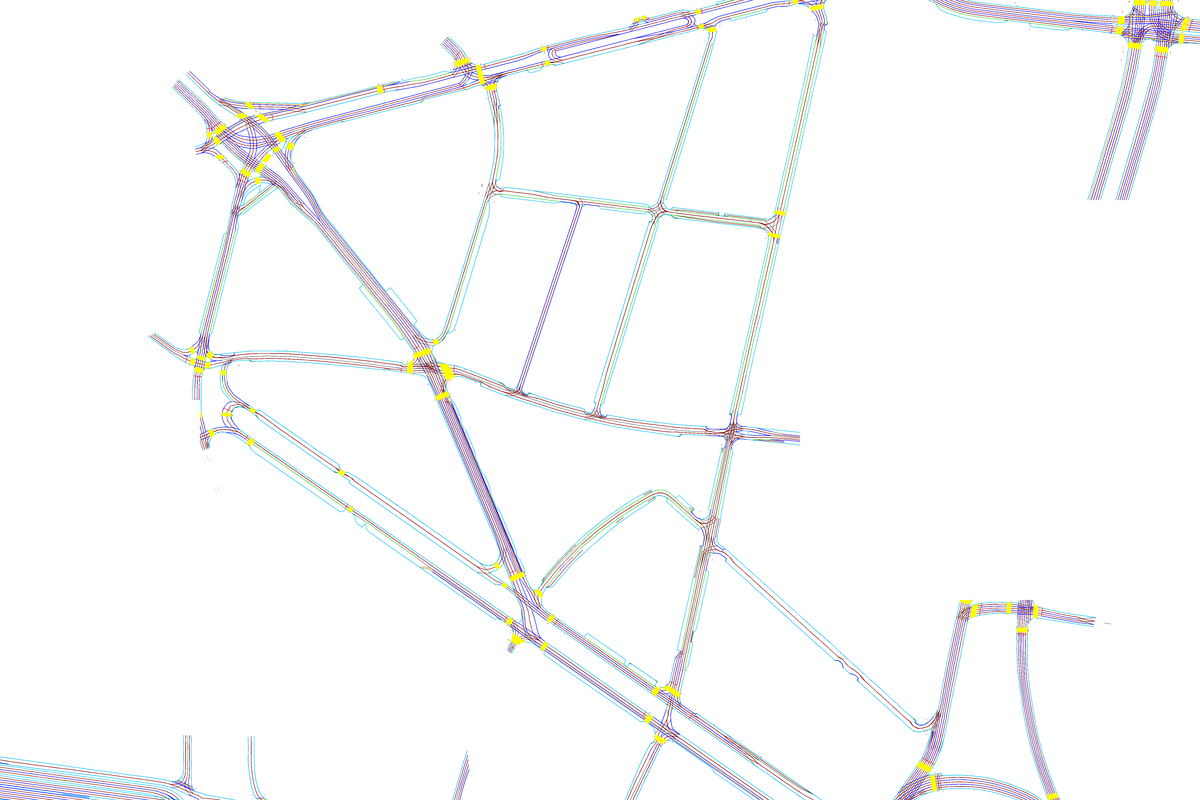
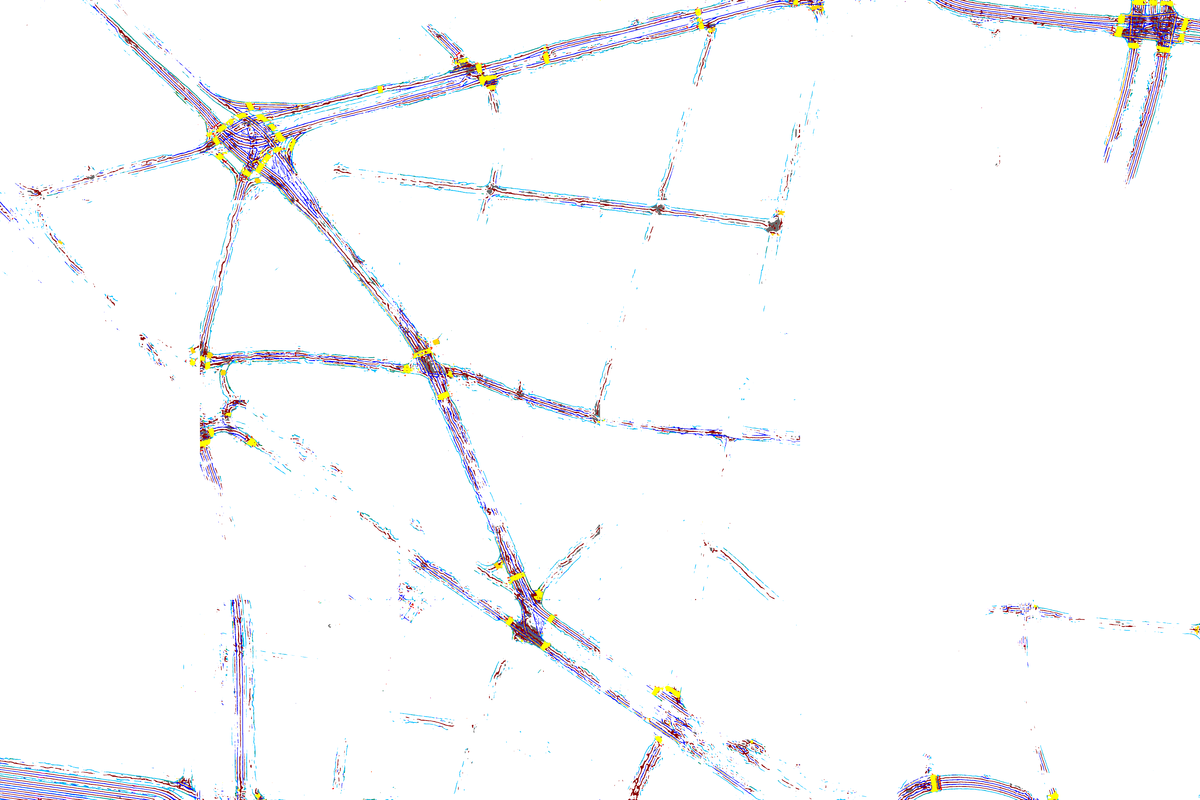
HD Maps extend the capabilities and reliability of autonomous vehicles both during operations and offline development of models. They are used as labels for training online HD map construction models and other map perception tasks used in autonomous driving stacks that rely less on static HD maps as well as in the generation of scenes for close-loop validation of End-to-End (E2E) driving models.
Additionally HD maps allow for more rigorous evaluation of E2E models in both open- and close-loop testing.
We research and develop methods to scale out the creation of HD maps using vehicle sensor data as well as aerial imagery and SD maps such as openstreetmap.
First we develop tooling for massively parallel and efficient HD map annotation by humans.
Second we develop automated test and verification systems as feedback and quality assurance.
Third we develop and train neural networks that infer HD maps and their components, on a city level scale.
This allows us to effectively scale mapping for highly data driven research applications such as deep learning.